Choosing a controller
What’s the best controller for a model locomotive? Literally thousands of our controllers have been used in model locos of all shapes and sizes over the last 30+ years. The model of controller you need depends on the power / current rating of your motors, and also the sort of loads that you intend to pull, any gradients on your track, and how long you intend to run for.
As a general guide the following controllers are suitable for model locos:
DNO range – These are great for small / mid size locos up to 5″ / 7¼ ” gauge – with motors up to 100 amps. These are simple controllers that require the minimum of set-up, with adjustable gain and ramp settings. We see good results for locos pulling up to around 10 passengers with these.
Pro-160 – fast becoming the standard for mid-size locos up to 5″/ 7” gauge. The Pro-160 does away with relays to give long term reliability, and is ideally suited to those locos that will be worked hard pulling 10 – 20 passengers for extended operating periods. With a 2 line display that can be mounted remotely the Pro-160 has features designed specifically for locomotive control, including a deadmans handle input, built in radio control input, and readouts of voltage, current, power, and temperature [motor temperature, speed, and RPM can also be monitored with external sensors]. The Pro-160-S has an upper current limit of 140A, whilst the Pro-160-HC can go all the way to 200A.
Pro-360 – for larger locos with motors up to 360 amps, these controllers provide serious pulling power. With deadmans handle, emergency stop, top speed limit, regen braking, and coasting all easily adjustable, they have all the features you need to make your loco run just the way you want it. There are also uprated air and water cooling options available.
One question that often comes up is whether to choose a controller that uses relays or not? At 4QD we use both approaches and here we’ll take a quick look at the pros and cons.
To make an electric motor go in reverse we need to change the polarity of the voltage supplied to it, and there are two common ways to do this.
Method 1 – is to use a half bridge controller arrangement and use relays to swap over the polarity.
The basic diagram looks like this, which is the circuit we use for the lower power controllers in our range such as the DNO and Pro-150.

Advantages of the half bridge and relay design
- Fewer mosfets are needed, the PCB can be smaller, and the mosfet drive circuit can be simpler, all of which makes for a less costly controller.
- The relays can be arranged to put a short circuit across the motor when stopped, providing a strong braking force.
- The motor current only ever flows through a single mosfet bank which means less heat will be dissipated.
Disadvantages of the half bridge and relay design
- The main issue with using relays is the longevity of the contacts. If the rating of the contacts is observed then the relays can last for a long time, for example our NCC series was designed back in 1993 and a lot of them are still in service 26 years later. However if the rating of the contacts is exceeded then problems can start to occur. Electric motors can draw stall currents sometimes three or more times greater than their rated value, and over time these momentary high currents can cause cumulative damage to the contacts which may eventually lead to failure.
- If very short deceleration ramp times are used, the relay contacts can open before the motor is fully stopped, this causes arcing which will erode the contacts and can generate sufficient electrical interference to damage the controller.
Method 2 – Full H-bridge
A full H bridge uses twice as many mosfets arranged in an H configuration to do the switching, thus doing away with the need for relays.
The basic diagram for an H-bridge looks like this, which is the circuit we use in our higher power controllers like the Pro-160 and 4QD series.

To go forward mosfets A and D are switched on, to go in reverse we switch on B and C.
Advantages of the H-bridge design
- There are no relays in the circuit so long term reliability is enhanced, particularly in higher load situations.
- Switching can be done very quickly which makes this design more suitable for say a robot which must change direction rapidly.
- There is no short circuit across the motor when stopped which means that that it is easier to push a vehicle with the power off.
Disadvantages of the H-bridge design
- Double the number of mosfets and bigger main capacitors are required for a given power level.
- Because there are two mosfet banks in circuit the heat dissipation may be greater.
- The circuit is more complicated. If software is used to control the switching it can get complex although modern chip design has mitigated this to a large extent.
In summary;
Half bridge controllers with relays are ok if;
- The controller is conservatively rated with respect to the motor.
- Gentle deceleration times are used.
- A smaller, more cost effective design is required.
Full H-bridge controllers without relays are better for
- Long term reliability.
- Any application where rapid stops are called for.
- The ability to push a vehicle is required.
The quick answer is quality and support. For instance…..
Support- We design and build our products ourselves, we know what goes into them, how they work, and have many years’ experience in sorting out all the little issues that can occur in the wide variety of projects that our customers build. You just don’t get that from Ebay or Alibaba. Our customer support team never leave a man behind – we keep going until your installation is working properly.
Capacitors – Some of our competitors don’t put in much by way of main capacitors, you can get away with this on the test bench but in the real world that often involves long, thin battery leads, this can result in the capacitors and mosfets working a lot harder than they should, getting hot, and failing early. We put in a lot of capacitance and we spread it around the board by fitting many smaller capacitors, this helps the heat dissipation and gives better ripple performance. But it takes time to fit them.
Mosfets – These are the heart of any motor controller. As I write this a single seller [Mouser] lists 2713 different TO220 mosfets. The range of parameters is large. We take the time to sift through this and carefully evaluate the mosfets we use. We’re looking at current ratings, turn on / turn off times, capacitance values, figures of merit, and many other factors to get the best we can.
Metalwork – It’s a fact – all controllers generate heat. It’s no good having the best mosfets in there if you can’t get the heat out. Our controllers have the mosfets bolted directly to substantial aluminium heatsinks. That said, if you want to run high currents for long periods then you’ll need to think about how to manage that heat, see this article on improving heat dissipation.
Repairability – It’s also a fact that controllers can fail, and there’s a whole variety of reasons why [see this article]. If you are unlucky enough to suffer one of these there is a good chance we can repair your controller, again you just don’t get that from some other suppliers. We’ve also written an article on best installation practise which will help you to stop this happening in the first place.
If you know the current rating you need you can select directly from our range page
We have a comparison table, a flowchart, and some common application guidelines that will help here.
We also have a page in our knowledge base that covers the basic physical principles.
If all else fails pick up the phone – we’re always happy to talk about your project.
Yes, some do. See the specification table for details. But if you are still designing your system you may want to read this page on why 24V is a better option.
Yes, most do. See a look at our specification table for details. Our new Pro-160 can go all the way to 84V.
Not quite yet – but we have got the prototype of our first brushless controller on the bench for testing so it won’t be long.
It will be broadly similar to our Pro-160, the same size and shape, and with a very similar set of features.
It is usually possible to tell the type of motor you have from the number of wires or terminals it has.
4QD controllers are designed to drive permanent magnet brushed motors, these generally have 2 external wires or terminals which are usually black and red to indicate positive and negative.
Series wound and shunt wound motors generally have 4 terminals, 2 for the field winding, and 2 for the armature. Our controllers are not specifically designed to drive these types of motors but a number of our customers have managed to do so successfully. There are some articles in our knowledgebase on how to do it.
Brushless motors will have either 3 wires for a sensorless version, or 3 + 6 sensor wires if they are fitted with hall effect sensors. We do not currently have any controllers for brushless motors, but we are looking into it.
You need to consider the motors rated current, and also it’s maximum stall current. We have a flowchart here that can help you decide.
Installation questions
If you have horns or relays fitted to your vehicle, you should fit catching diodes, one across each device to prevent a damaging voltage spike.
Horns, particularly car or motorcycle types can be very electrically inductive, this means that when the current through them is switched off, a large voltage spike will be generated. This voltage spike can be large enough to affect the operation of a controller, and in the worst case to damage it.
Fitting a catching diode helps manage the way that the current decays through the horn and prevents the voltage spike.
The diode should be fitted across the horn or relay as shown

We’ve got a more detailed article on the subject here.
Electric motors are electrically noisy, the sparks commonly seen at the brushes are a source of radio frequency interference [RFI] that can cause problems with both the host controller and other systems [have a look at this video of brush arcing]. Historical fact; Marconi used an arc to transmit the first radio signal across the Atlantic.
A new motor and a properly designed motor controller may go on working for years without suffering problems, but over time the arcing and RFI will get worse, and there is a statistical probability of an energy spike of just the right parameters to blow a MOSFET.
Fitting motor noise suppression components, and following these installation guidelines will significantly improve the long term system reliability by reducing the chance of MOSFET latch up and failure.
Have a look at this short video to see examples of a motor with and without noise suppression…..
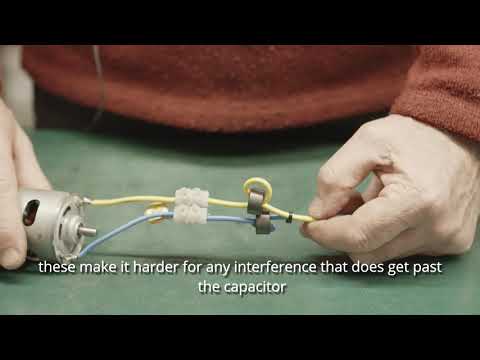
Watch this video to find out.
Yes. All 4QD controllers can be controlled by a voltage input.
You can use a DAC to provide a voltage output, or use a PWM output directly. We have tested 4QD controllers with PWM inputs between 10Hz and 10kHz.
Yes but be aware that with the high currents that our controllers can switch, come some constraints on mains power supplies. All our controllers use use 20kHz chopping and a transformer fed full wave rectified mains power supply will have a 100Hz or (120Hz in USA) output so you will need to have very good smoothing. Except at relatively low currents, a suitable transformer, rectifier and reservoir capacitor can prove very expensive, so a small battery with a suitable charger is a good [and often cheaper] alternative.
If you use a switch-mode mains supply, you should consider its operating frequency and how it will perform under full motor current chopped at 20kHz.
The main capacitor on the controllers is intended to be sufficient when used from a battery – which itself acts like a large capacitance. For high current use of a power supply you are probably going to require a lot of (expensive) extra capacitance here.
One other issue to be aware of is the voltages developed by regenerative braking. Many of our controllers feed power back into the battery during braking. If there is no battery then the regenerated energy can pump up the power supply voltage to a high level if the motor is stopped too quickly. Although our controllers are protected against such over-voltage, it may damage your power supply.
Yes,it is possible to have two or more controllers driving multiple motors. In the Loco worls it is called “double heading” and we have a number of diagrams in our knowledge base that show how this can be done.
Yes, our controllers don’t care how many motors they are connected to, so long as the maximum current rating is not exceeded. The current record is eight.
Having an ammeter and a voltmeter in the circuit gives a lot of information about what is going on.
An ammeter can tell you:
- about the load that the motor is currently pulling
- about the direction of current flow
- about faults with the motor.
A voltmeter can tell you about the state of charge of the batteries, as the battery discharges, its voltage drops, and this can be used to indicate the charge state of the battery.
Our Pro-100, 160, and 360 controllers have built in current and voltage meters. As well as showing the values on the display, the software allows you to set limits to the drive and regen currents, and also to implement advanced battery protection measures.
Note: Using voltage as an indication of battery capacity has a couple of drawbacks;
- Due to the internal resistance of the battery, as the current increases the voltage will fall.
- The technique is not very accurate with lithium batteries. These only have a very small voltage drop across their capacity range.
Our Pro-100, 160, and 360 controllers now have software that takes account of the current when giving a low voltage warning. They also have a feature called Coulomb Counting which is a much more accurate way of monitoring remaining battery capacity.
We often get asked what voltage should be used to give the best performance? To answer this question we need to have a quick look at power, what it is, and where it goes.
To give a vehicle a certain performance takes a particular level of power. This power level depends on the mass of the vehicle, the top speed of the vehicle, the acceleration rate you require and the gradients it must climb.
In an electric vehicle the power comes from the battery. Electrical power is volts multiplied by amps so that 40 amps from a 12v battery is 480 watts. But 480 watts is also given from a 24v battery by a current of only 20 amps. For a particular power, the higher the voltage, the lower the current.
Now electrical current causes heating. The motor, wiring and controller will all get hot and waste power. The heat wasted is proportional to the square of the current multiplied by the resistance. Moving from 12V to 24V halves the current but halving the current reduces the heating losses to a quarter.
It is clear from this that a 24V system is always better than a 12V system – provided you can physically fit two batteries. By the same token 36V or 48V would be even better, heavy duty systems such as fork lift trucks often use 96V, electric cars are now using 600V!
The amount of energy in the batteries is amps X hours X volts. Consider a 12V 60 Ampere Hour battery. Clearly this is exactly the same as two smaller 12V 30 AH batteries in parallel. But the total amount of energy in these two will not change whether we connect them in parallel or in series. So a 12v 60 AH battery can store exactly the same energy as a 24v 30 AH battery.
There is another factor against 12V operation, except at low currents: MOSFETs need a good voltage to fully turn them on, almost all of 4QD’s controllers use an internal 9v supply rail, which is adequate to ensure proper turn-on. However, there is not much difference between 9V and 12V. It does not take much current to be drawn from the battery before it drops 2V at its terminals. A small mount of extra drop in the wiring and the internal 9V supply drops. After that, the available current from the controller drops quite quickly! Remember that the battery current is actually a chopped version of the motor current, see our circuits archive for more detail, so the inductance and resistance of the batteries and battery wiring all contribute to any voltage drop.
For this reason, we would generally not advise 12v operation if the peak motor current is likely to be more than around 30-50 amps.
Features
Closed loop control
The Pro-100, Pro-160, and Pro-360 have a speed sensor input which can be used to set a top speed limit. We do have PID software available for these models but this requires tuning for each application and is not part of the standard software. Contact 4QD support for more details.
The Pro-150, 4QD series, DNO, and Porter controllers can have closed loop control implemented via our tacho feedback board.
Constant torque mode is the same as constant current control. The Pro-100 / 160 / 360 have direct motor current sensing and uses this to implement a fully adjustable current limit. The software to provide a full torque control mode is being developed.
Disabling regen braking can be done on certain models
- The Pro-100 / 160 / 360 have regen braking that is fully adjustable in the menu.
- The following controllers can have regen braking disabled by an on-board link
- 4QD series
- Pro-120 Mk 2
- VTX series
- The following controllers can have regen braking disabled by cutting PCB tracks
- DNO series
- Porter
- The following controllers have regen braking which cannot be disabled
- Pro-150
A variety is the answer. Full details are in the comparison table on this page but all have adjustable acceleration and deceleration ramps.
Batteries
If you don’t think your battery life is all that it should be then;
- Check the battery condition. The capacity of a battery reduces as it gets older. Also do a load test on it, we’ve seen batteries that gave 12.8V off load but that dropped to 11.1V as soon as a load was applied.
- Check the condition of the power cabling. We’ve seen numerous cases where cable joints have degraded over time, overheated, and then caused a significant volt drop at the controller. Measure the voltage directly across the controller B+ & B- terminals whilst under load.
- Is there mechanical drag in the system?
- If all else fails, fit bigger batteries. The controller can only do only one thing with the current it takes from the battery – pass it on to the motors. If the controller wasted any significant power – it would simply get hot and go up in smoke, so if the batteries don’t last – it’s a battery, a motor, a wiring, or a mechanical problem.
Yes….But….!
The great majority of lithium batteries now have a built-in battery management system [BMS] which protects the battery by sensing the voltage of each individual cell and the current flowing through it. If the cell voltage gets too low or too high, or if the discharge or charging current gets too high, the BMS will protect the battery by disconnecting it from the load. This disconnection can have serious consequences for a motor controller.
Our Pro-160 / 360 have settings that can prevent this damage, in short you need to do the following….
- Set the under-voltage cut off point of the controller to be above that of the BMS, that way the controller will ensure a controlled stop before the BMS trips. The Pro-160 / 360 both have a low battery warning level that can be set higher than the BMS cut-off level that will allow a “limp home” mode under reduced power.
- Set the over-voltage limit of the controller to be below the maximum charge voltage of the BMS. The controller will automatically adjust the deceleration ramp rate to keep the regeneration voltage below the BMS cut-off level.
- Set the maximum current limit of the controller to be below that of the BMS, that way the controller will make sure that the BMS does not reach its threshold for tripping.
- Set the regen current limit of the controller to be below that of the maximum charge current of the BMS, that way the controller will make sure that the BMS does not reach its threshold for tripping.
We’ve written a more in depth article on this subject here.
On our other, older controllers it is possible to have a low voltage cut-off, but full current and over-voltage limiting is not possible.
- The DNO can have a simple modification done to set a low voltage cut-off.
- Our BCM-5P1 battery meter has a low battery cut-off feature.
- The 4QD-200 / 300 series have an adjustable current limit and low voltage cut-off.
Miscellaneous
We’re often asked to talk about brushed v brushless motors so here goes…..[we’ll put some pictures in here in due course but for now it’s just words].
Brushed motors have been around for ages, they are;
- Simple – put a voltage across them and off they go.
- Cheaper.
- Less efficient – typically around 75%.
- Noiser, both physically and electrically.
- Brushes will wear out over time – typically 1000 – 3000 hours.
Brushless motors on the other hand tend to be;
- More efficient due to less friction – around 90%+.
- Quieter, both physically and electrically.
- Longer lasting – typically 10 000 hours.
- Able to run at higher speeds.
- But – they need a more sophisticated controller to make them move.
So why do brushless motors need a more complicated controller? In a brushed motor as the armature rotates, the brushes and commutator switch the voltage between the successive windings, making in effect a mechanical switch. In a brushless motor this mechanical switch is not there and thus the switching has to be done electronically by the controller. To do this switching the controller needs to know about the position and speed of the armature, it can get this information either from Hall sensors on the outside of the motor or by sensing the voltage induced in the stator coils [sensorless mode].
Multiple motors. A controller for a brushed motor does not care how many motors are connected to it so long as the overall current rating is not exceeded, our current record is a single controller driving eight motors. But this does not apply for brushless controllers, because the controller needs to know about the position of the armature a single controller can only drive a single brushless motor. Note, there are dual channel brushless controllers that can drive two motors, but the general principle that you cannot just add motors in parallel to an existing controller still holds true.
Motor types. A brushless controller needs to be told quite a lot about the motor it is working with e.g. inductance, resistance, pole pairs, threshold speed etc. This is not the case with brushed.
Regenerative braking. For a brushed motor regen braking is relatively easy and done by quite straightforward switching within the controller. But with brushless motors more sophisticated measurement and switching is required, and our experience is that regen is difficult to do well without significant investment in software.
Why do speed controllers sometimes fail?
Here at 4QD we go to a lot of trouble to make sure our controllers are reliable. We make sure we have enough capacitance, we use the best mosfets we can find, we fit substantial heatsinks, we minimise the susceptibility to radiated and conducted noise, and we conduct extended life tests by running controllers on an automated test rig.
And yet very occasionally a customer will get a seemingly random failure. Actually there’s a clue in that sentence, in five years we’ve not had a single mosfet failure on our test rigs, the reason for that is that we take a lot of care with electrical noise suppression. Motors are electrically noisy things, just look at the back of an old electric drill to see the sparks. We’ve written a full article in our knowledgebase about motor noise and how to prevent it, it also describes other sources of noise, and some detail on mosfet failure modes. It’s well worth 10 minutes of your time reading this and taking the necessary steps to make sure that your controller doesn’t suffer an untimely end. If you just want the short “what do I need to do?” version have a look here.
We’re now shameless about plugging our suppression components. They don’t cost a lot but since we introduced them we have seen the field failure rate of our controllers drop significantly.
Increase the voltage. If you have a single 12V battery, consider fitting 2 smaller ones and connecting them in series to give 24V. It is possible to arrange for a 24V system to charge from a 12V source, this page shows how. Bear in mind that if you double the voltage you will get four times the power.